
Description
WDS Horizontal Steering Wheel for AGV and AMR Automation Systems
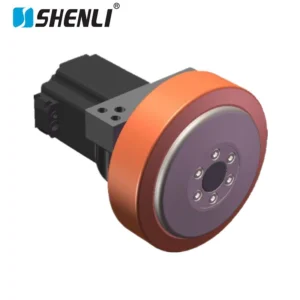
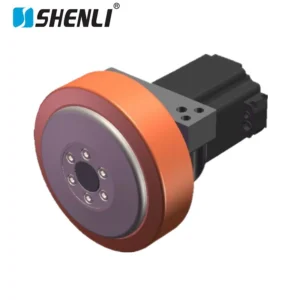
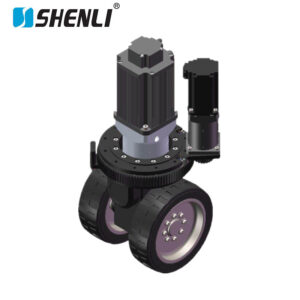
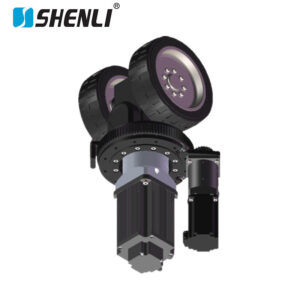
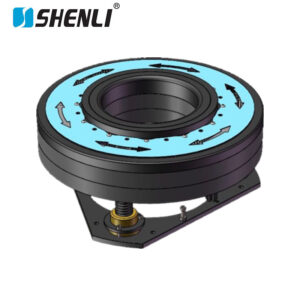
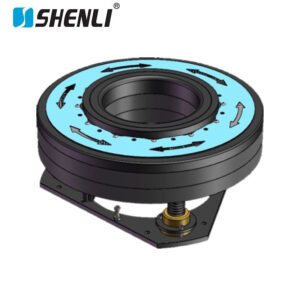
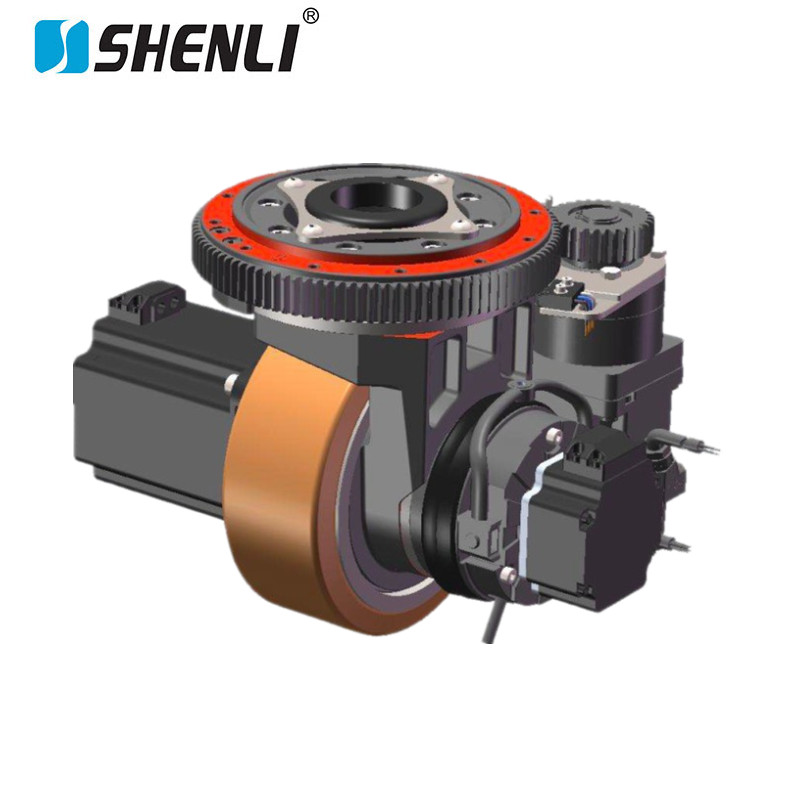
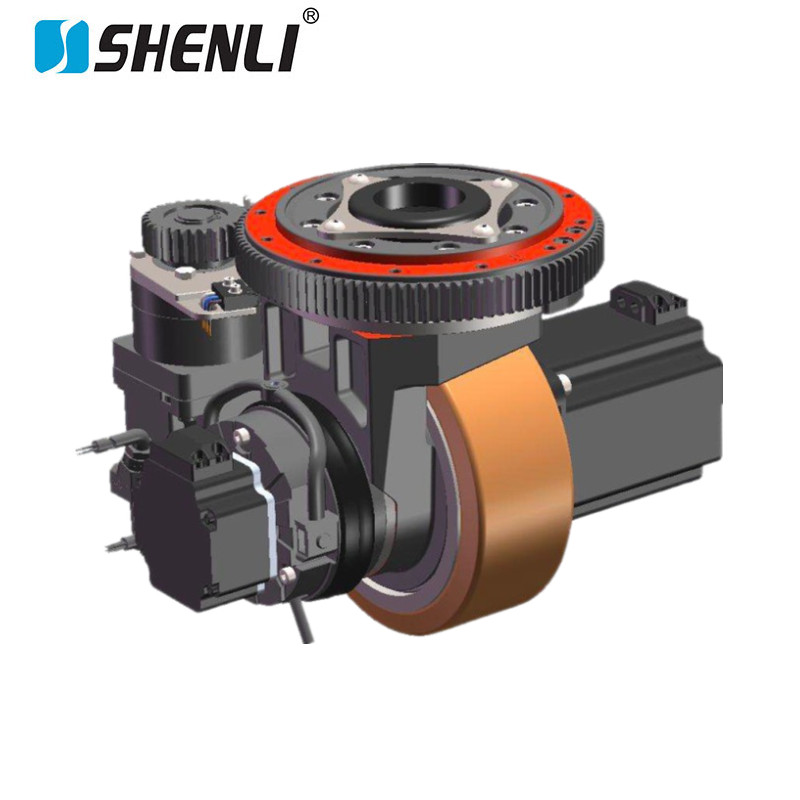
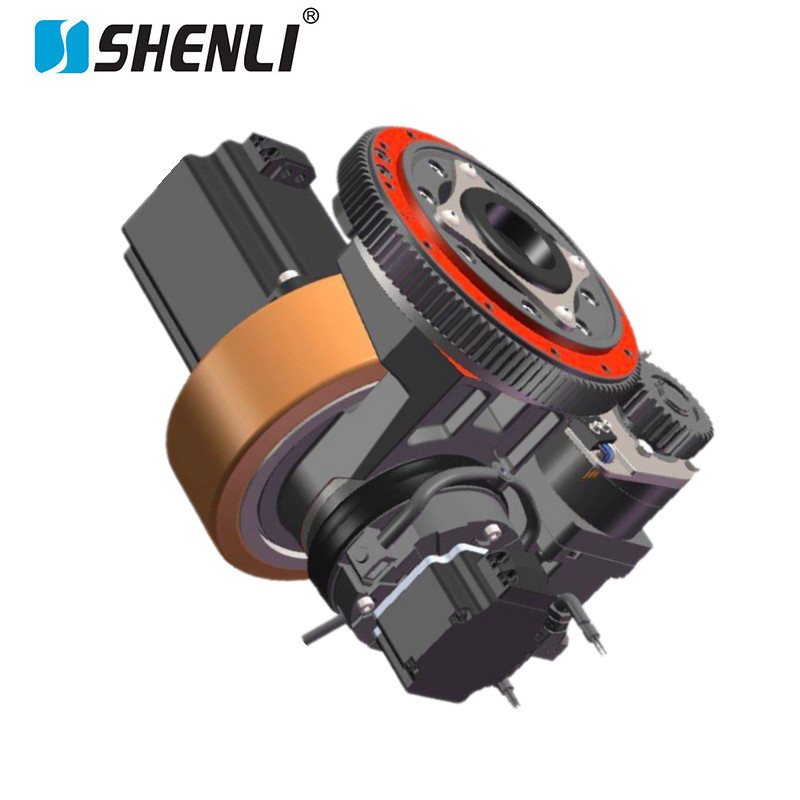
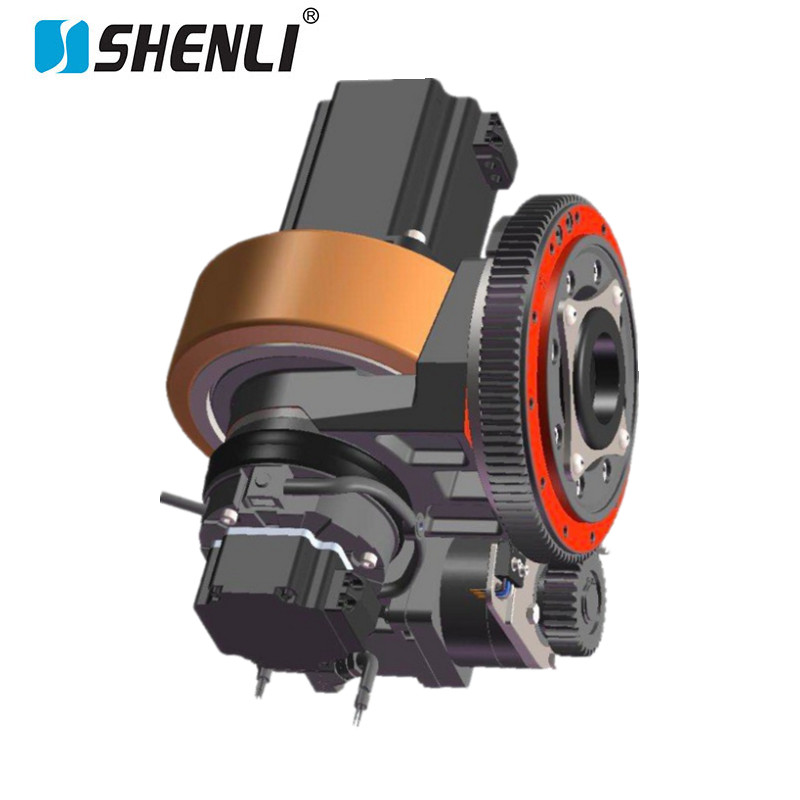
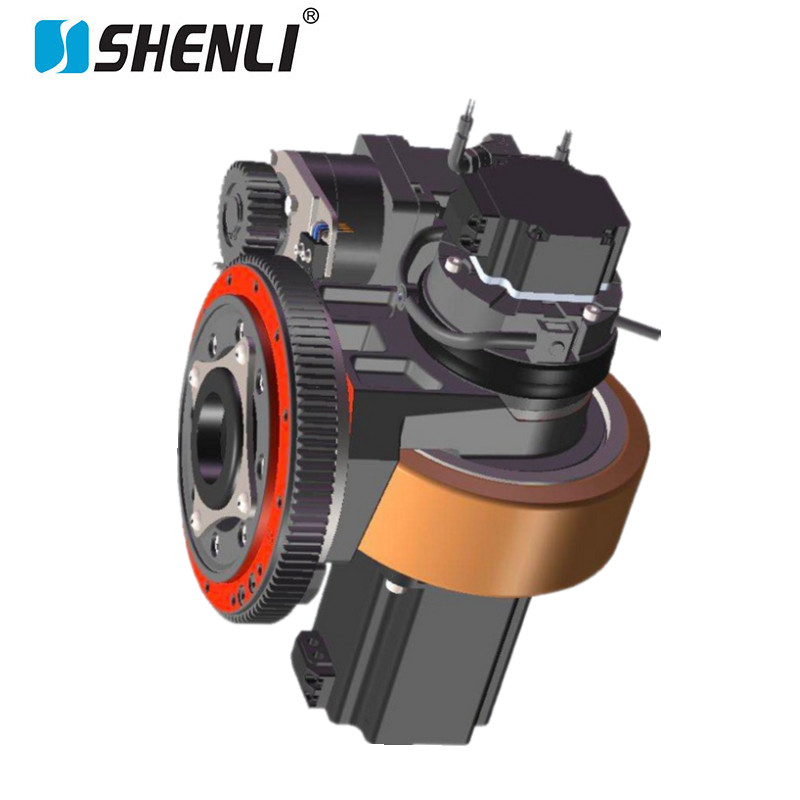
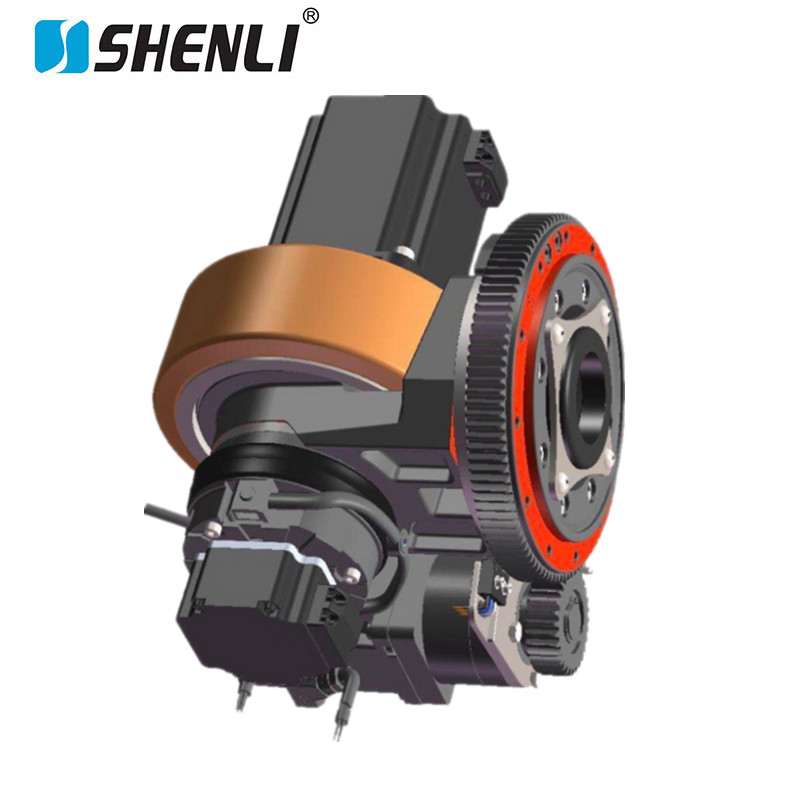
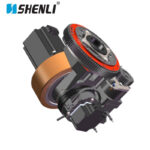
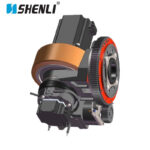
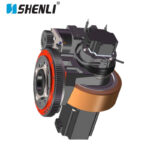
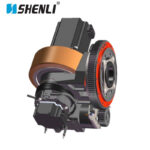
SHENLI develops advanced motion control components for automated material handling equipment. The WDS horizontal steering wheel integrates driving and steering functions into a compact AGV drive steering module, providing efficient movement control for autonomous vehicles.
Designed for AGV manufacturers, AMR system integrators, warehouse automation companies, and industrial mobile platform builders, this integrated steering wheel solution delivers precise navigation, high load capacity, and flexible multi-directional movement.
By combining a steering actuator, drive motor, and high-traction wheel system in one compact structure, the WDS module helps equipment manufacturers optimize chassis design while improving overall motion performance.
Compact Drive and Steering Integration for Space-Limited AGVs
The WDS horizontal steering wheel adopts a horizontal coaxial or offset structure that combines traction and steering mechanisms into a single assembly.
This compact design reduces vertical installation requirements and creates additional internal space for batteries, control systems, and payload areas. As a result, it is ideal for low-profile AGVs, autonomous forklifts, and mobile robotic platforms that require efficient space utilization.
High-Torque Motion Control and Precise Navigation
Equipped with servo motor drive options, the WDS steering module supports smooth acceleration, fast direction changes, and accurate trajectory control.
The optimized motion system reduces vibration during operation and maintains stable movement when AGVs navigate narrow aisles, sharp turns, and complex factory environments.
This reliable performance makes the module suitable for applications that require continuous material transportation and precise positioning.
Heavy-Duty Mechanical Structure for Industrial Operation
SHENLI manufactures the WDS steering wheel using high-strength alloy steel components and precision CNC machining processes.
The reinforced housing structure withstands mechanical impact, torsional stress, and continuous industrial workloads. Integrated precision bearings distribute radial and axial forces evenly, supporting stable operation in high-frequency warehouse and manufacturing environments.
High-Traction Polyurethane Wheel for Reliable Floor Contact
The WDS module uses an industrial polyurethane wheel designed for demanding factory conditions.
The polyurethane tread provides low rolling resistance, excellent wear resistance, oil resistance, and non-marking performance. It maintains reliable traction on epoxy floors, smooth concrete surfaces, and slightly uneven industrial ground.
This wheel design helps AGVs achieve stable movement, controlled braking, and reduced floor damage during daily operation.
Customized AGV Drive Steering Solutions from SHENLI
As an experienced industrial motion control manufacturer, SHENLI provides customized AGV and AMR steering solutions based on different vehicle structures and application requirements.
Customers can optimize motor specifications, steering configurations, wheel designs, and mechanical interfaces to match specific automation projects.
With advanced manufacturing capabilities and strict quality control, SHENLI delivers reliable WDS horizontal steering wheels for warehouse automation, smart factories, and autonomous mobile robotics.
Typical Applications
AGV automated guided transport systems.
Smart warehouse logistics systems.
Industrial automated handling platforms.
Intelligent factory mobile robots.
Flexible production line equipment.
Unmanned handling systems.
Heavy-duty logistics transfer systems.
WDS Horizontal Steering Wheel – Product Specifications & Technical Details
The WDS Horizontal Steering Wheel is a high-performance integrated steering and driving module designed for AGV (Automated Guided Vehicle), AMR (Autonomous Mobile Robot), and intelligent material handling systems. The module combines compact structure, precision steering control, and high-load traction capability to meet demanding industrial automation applications.
Technical Specifications
- Product Name: WDS Horizontal Steering Wheel
- Product Type: Integrated AGV Steering Drive Module
- Steering Structure: Horizontal Steering Design
- Drive Mode: Servo Motor / Brushless Motor Compatible
- Wheel Configuration: Drive & Steering Integrated Module
- Wheel Material: High Wear-Resistant Polyurethane / Rubber Optional
- Frame Material: High-Strength Aluminum Alloy / Steel Structure
- Load Capacity: Suitable for Medium and Heavy-Duty AGV Systems
- Steering Accuracy: High Precision Directional Control
- Rotation Angle: 360° Continuous Steering Capability
- Transmission Type: Precision Gear Transmission System
- Motor Compatibility: Servo Motor, Closed-Loop Motor, Brushless DC Motor
- Gearbox Compatibility: Planetary Gearbox / Precision Reducer Optional
- Control System Support: AGV Controller / PLC / Motion Control System
- Encoder Option: Absolute Encoder / Incremental Encoder
- Installation Method: Bottom Mount / Customized Mounting Structure
- Operating Voltage: Customizable According to System Requirements
- Speed Performance: Stable High-Speed Motion Control
- Protection Features: Dustproof & Industrial Protection Design
- Maintenance Requirement: Low Maintenance Structure
- Operating Environment: Warehouse, Factory, Logistics Center, Smart Manufacturing Facility
Product Features
- Compact horizontal steering structure for optimized installation space
- Integrated steering and drive system for simplified AGV design
- High load-bearing capability for industrial transport applications
- Smooth steering response and stable traction performance
- High-strength wheel material with excellent abrasion resistance
- Precision steering control for autonomous navigation systems
- Low vibration and low noise during continuous operation
- Flexible customization available for different AGV and AMR platforms
- Long operational lifespan under intensive industrial environments
- Suitable for 24/7 automated logistics operation systems
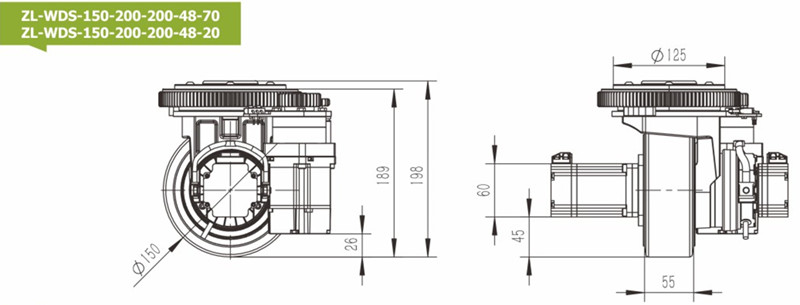
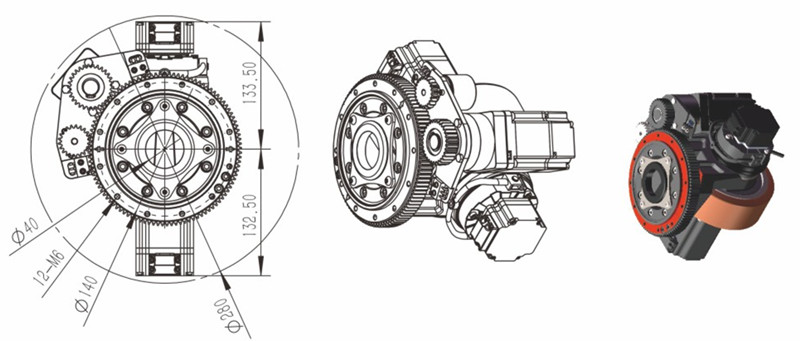
ZL-WDS-150-200-200-48-70(20)
| Traction motor parameters | Motor Power | Motor Voltage | Motor speed | Motor current | Rated torque | IP Grade | Encoder | ||
| Type | DC | W | V | RPM | A | Nm | IP | Magnetic braiding | Resolution ratio |
| Servo Motor | 200 | 48 | 3000 | 5.1 | 0.64 | 65 | Increment | 1024 | |
| Traction reducer parameters | Type | X | Planetary reducer | Steering motor parameters | Type | DC | Servo Motor | ||
| Reducer speed ratio | i | 20 | 68 | Motor Power | W | 200 | |||
| Reducer torque | Nm | 100 | 120 | Motor Voltage | V | 48 | |||
| Polyurethane Loaded | Kg | 1000 | Motor speed | RPM | 3000 | ||||
| Rubber Loaded | Kg | 900 | Motor current | A | 5.1 | ||||
| Braking torque | Nm | 76 | 258.4 | Reducer speed ratio | i | 35+(105:30) | |||
| Actuators torque | Nm | 4 | 4 | Reducer torque | Nm | 35 | |||
| Actuators Voltage | V | DC24 | DC24 | IP Grade | IP | 65 | |||
| Maximum speed | M/min | 70.7 | 20.8 | Encoder | Magnetic braiding | Increment | |||
| Traction | N | 162 | 522.24 | Resolution ratio | 1024 | ||||
| Traction weight | reference | 292 | 835.584 | Left and right limit | IO | Always on, always off | |||
| Max steering Angle | ± | 140° | |||||||
| Another | Reducer lubrication | lubricant | (-20°~200°) | ||||||
| Dead-weight | Kg | About16 | |||||||
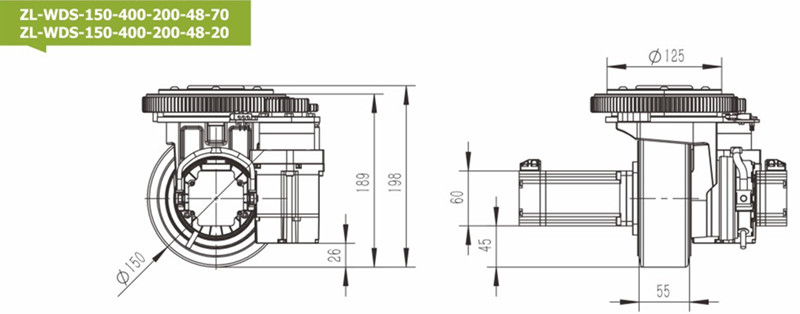
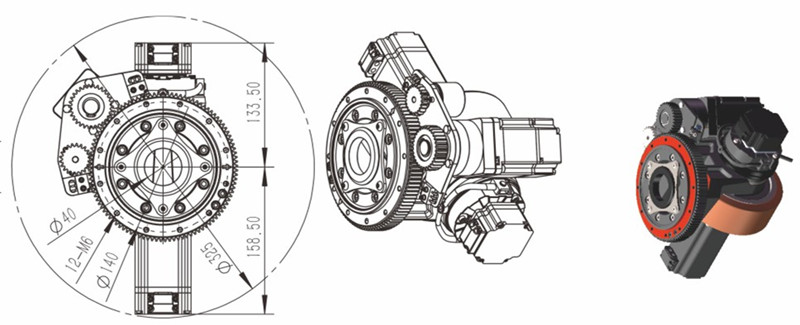
ZL-WDS-150-400-200-48-70(20)
| Traction motor parameters | Motor Power | Motor Voltage | Motor speed | Motor current | Rated torque | IP Grade | Encoder | ||
| Type | DC | W | V | RPM | A | Nm | IP | Magnetic braiding | Resolution ratio |
| Servo Motor | 400 | 48 | 3000 | 10.1 | 1.27 | 65 | Increment | 1024 | |
| Traction reducer parameters | Type | X | Planetary reducer | Steering motor parameters | Type | DC | Servo Motor | ||
| Reducer speed ratio | i | 20 | 68 | Motor Power | W | 200 | |||
| Reducer torque | Nm | 100 | 120 | Motor Voltage | V | 48 | |||
| Polyurethane Loaded | Kg | 1000 | Motor speed | RPM | 3000 | ||||
| Rubber Loaded | Kg | 900 | Motor current | A | 5.1 | ||||
| Braking torque | Nm | 76 | 258.4 | Reducer speed ratio | i | 35+(105:30) | |||
| Actuators torque | Nm | 4 | 4 | Reducer torque | Nm | 35 | |||
| Actuators Voltage | V | DC24 | DC24 | IP Grade | IP | 65 | |||
| Maximum speed | M/min | 70.7 | 20.8 | Encoder | Magnetic braiding | Increment | |||
| Traction | N | 322 | 1036.3 | Resolution ratio | 1024 | ||||
| Traction weight | reference | 547 | 1658 | Left and right limit | IO | Always on, always off | |||
| Max steering Angle | ± | 140° | |||||||
| Another | Reducer lubrication | lubricant | (-20°~200°) | ||||||
| Dead-weight | Kg | About16 | |||||||
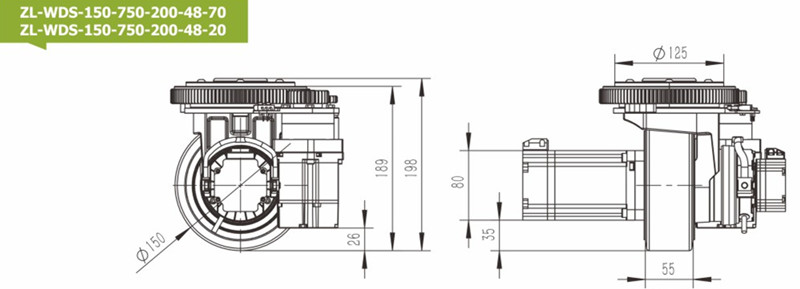
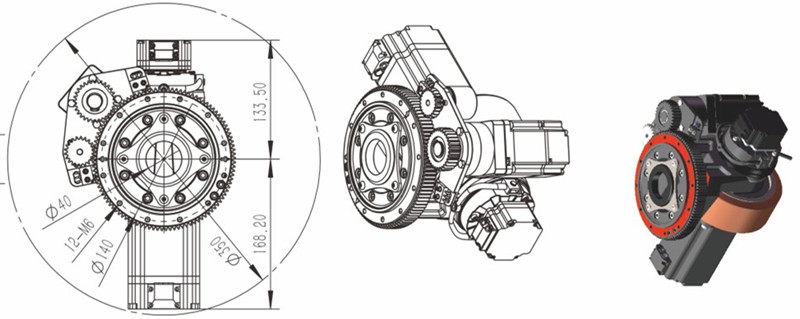
ZL-WDS-150-750-200-48-70(20)
| Traction motor parameters | Motor Power | Motor Voltage | Motor speed | Motor current | Rated torque | IP Grade | Encoder | ||
| Type | DC | W | V | RPM | A | Nm | IP | Magnetic braiding | Resolution ratio |
| Servo Motor | 750 | 48 | 3000 | 19 | 2.39 | 65 | Increment | 1024 | |
| Traction reducer parameters | Type | X | Planetary reducer | Steering motor parameters | Type | DC | Servo Motor | ||
| Reducer speed ratio | i | 20 | 68 | Motor Power | W | 200 | |||
| Reducer torque | Nm | 100 | 120 | Motor Voltage | V | 48 | |||
| Polyurethane Loaded | Kg | 1000 | Motor speed | RPM | 3000 | ||||
| Rubber Loaded | Kg | 900 | Motor current | A | 5.1 | ||||
| Braking torque | Nm | 76 | 258.4 | Reducer speed ratio | i | 35+(105:30) | |||
| Actuators torque | Nm | 4 | 4 | Reducer torque | Nm | 35 | |||
| Actuators Voltage | V | DC24 | DC24 | IP Grade | IP | 65 | |||
| Maximum speed | M/min | 70.7 | 20.8 | Encoder | Magnetic braiding | Increment | |||
| Traction | N | 605 | 1733.55 | Resolution ratio | 1024 | ||||
| Traction weight | reference | 1029 | 2600.32 | Left and right limit | IO | Always on, always off | |||
| Max steering Angle | ± | 140° | |||||||
| Another | Reducer lubrication | lubricant | (-20°~200°) | ||||||
| Dead-weight | Kg | About17 | |||||||
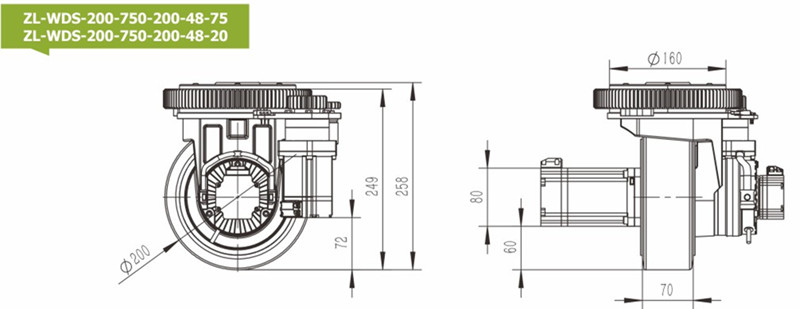
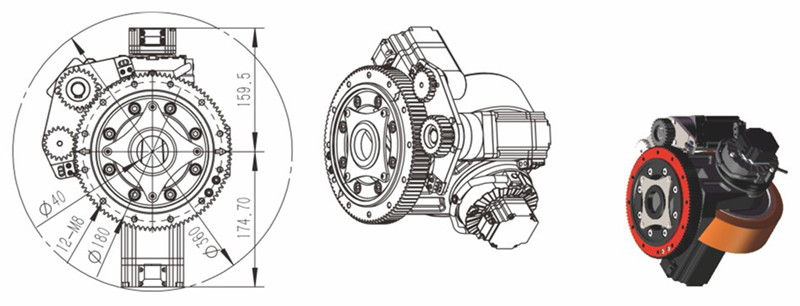
ZL-WDS-200-750-200-48-75(20)
| Traction motor parameters | Motor Power | Motor Voltage | Motor speed | Motor current | Rated torque | IP Grade | Encoder | ||
| Type | DC | W | V | RPM | A | Nm | IP | Magnetic braiding | Resolution ratio |
| Servo Motor | 750 | 48 | 3000 | 19 | 2.39 | 65 | Increment | 1024 | |
| Traction reducer parameters | Type | X | Planetary reducer | Steering motor parameters | Type | DC | Servo Motor | ||
| Reducer speed ratio | i | 25 | 85 | Motor Power | W | 200 | |||
| Reducer torque | Nm | 250 | 310 | Motor Voltage | V | 48 | |||
| Polyurethane Loaded | Kg | 1500 | Motor speed | RPM | 3000 | ||||
| Rubber Loaded | Kg | 1380 | Motor current | A | 5.1 | ||||
| Braking torque | Nm | 190 | 646 | Reducer speed ratio | i | 35+(100:25) | |||
| Actuators torque | Nm | 8 | 8 | Reducer torque | Nm | 35 | |||
| Actuators Voltage | V | DC24 | DC24 | IP Grade | IP | 65 | |||
| Maximum speed | M/min | 75.4 | 22.2 | Encoder | Magnetic braiding | Increment | |||
| Traction | N | 568 | 1218.9 | Resolution ratio | 1024 | ||||
| Traction weight | reference | 851 | 1828.35 | Left and right limit | IO | Always on, always off | |||
| Max steering Angle | ± | 140° | |||||||
| Another | Reducer lubrication | lubricant | (-20°~200°) | ||||||
| Dead-weight | Kg | About24 | |||||||
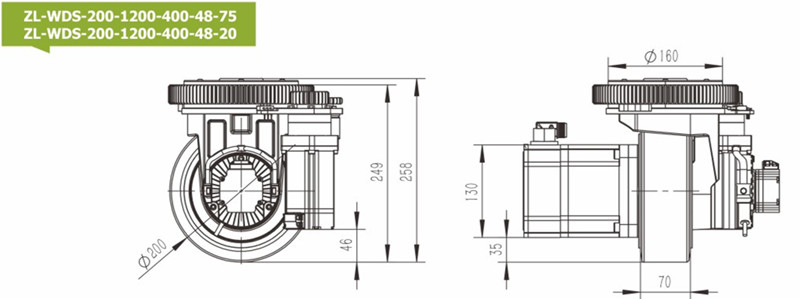
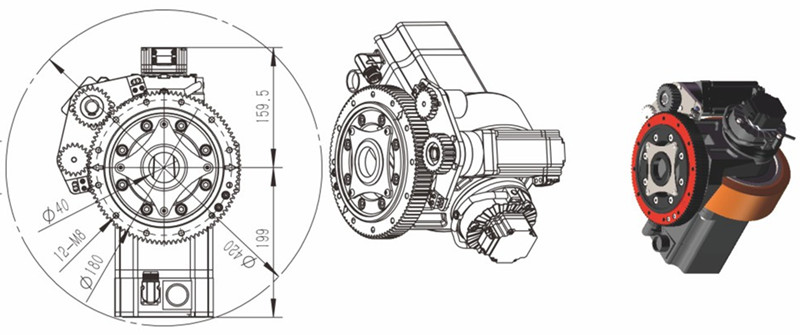
ZL-WDS-200-1200-400-48-75(20)
| Traction motor parameters | Motor Power | Motor Voltage | Motor speed | Motor current | Rated torque | IP Grade | Encoder | ||
| Type | DC | W | V | RPM | A | Nm | IP | Magnetic braiding | Resolution ratio |
| Servo Motor | 1200 | 48 | 3000 | 31.6 | 3.8 | 65 | Increment | 1024 | |
| Traction reducer parameters | Type | X | Planetary reducer | Steering motor parameters | Type | DC | Servo Motor | ||
| Reducer speed ratio | i | 25 | 85 | Motor Power | W | 400 | |||
| Reducer torque | Nm | 250 | 310 | Motor Voltage | V | 48 | |||
| Polyurethane Loaded | Kg | 1500 | Motor speed | RPM | 3000 | ||||
| Rubber Loaded | Kg | 1380 | Motor current | A | 10.1 | ||||
| Braking torque | Nm | 190 | 646 | Reducer speed ratio | i | 35+(100:25) | |||
| Actuators torque | Nm | 8 | 8 | Reducer torque | Nm | 35 | |||
| Actuators Voltage | V | DC24 | DC24 | IP Grade | IP | 65 | |||
| Maximum speed | M/min | 75.4 | 22.2 | Encoder | Magnetic braiding | Increment | |||
| Traction | N | 903 | 1615 | Resolution ratio | 1024 | ||||
| Traction weight | reference | 1354 | 2422.5 | Left and right limit | IO | Always on, always off | |||
| Max steering Angle | ± | 140° | |||||||
| Another | Reducer lubrication | lubricant | (-20°~200°) | ||||||
| Dead-weight | Kg | About25 | |||||||
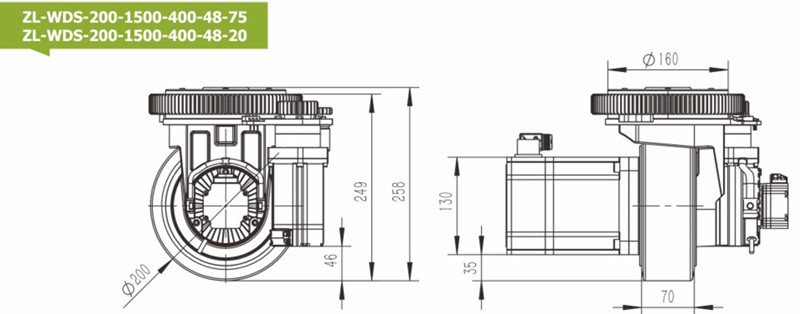
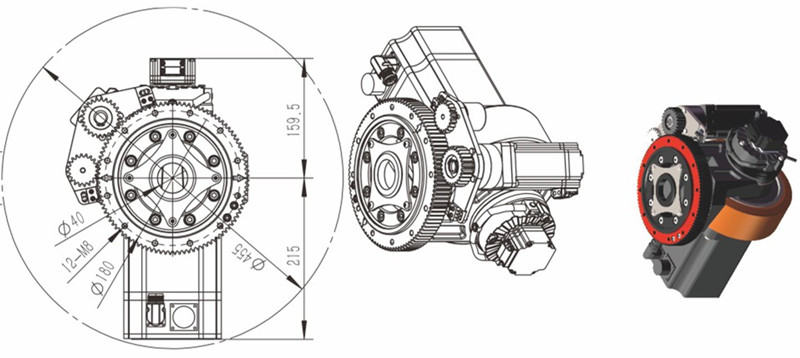
ZL-WDS-200-1500-400-48-75(20)
| Traction motor parameters | Motor Power | Motor Voltage | Motor speed | Motor current | Rated torque | IP Grade | Encoder | ||
| Type | DC | W | V | RPM | A | Nm | IP | Magnetic braiding | Resolution ratio |
| Servo Motor | 1500 | 48 | 3000 | 37.4 | 5 | 65 | Increment | 1024 | |
| Traction reducer parameters | Type | X | Planetary reducer | Steering motor parameters | Type | DC | Servo Motor | ||
| Reducer speed ratio | i | 25 | 85 | Motor Power | W | 400 | |||
| Reducer torque | Nm | 250 | 310 | Motor Voltage | V | 48 | |||
| Polyurethane Loaded | Kg | 1500 | Motor speed | RPM | 3000 | ||||
| Rubber Loaded | Kg | 1380 | Motor current | A | 10.1 | ||||
| Braking torque | Nm | 190 | 646 | Reducer speed ratio | i | 35+(100:25) | |||
| Actuators torque | Nm | 8 | 8 | Reducer torque | Nm | 35 | |||
| Actuators Voltage | V | DC24 | DC24 | IP Grade | IP | 65 | |||
| Maximum speed | M/min | 75.4 | 22.2 | Encoder | Magnetic braiding | Increment | |||
| Traction | N | 1188 | 2125 | Resolution ratio | 1024 | ||||
| Traction weight | reference | 1781 | 3187.5 | Left and right limit | IO | Always on, always off | |||
| Max steering Angle | ± | 140° | |||||||
| Another | Reducer lubrication | lubricant | (-20°~200°) | ||||||
| Dead-weight | Kg | About26 | |||||||
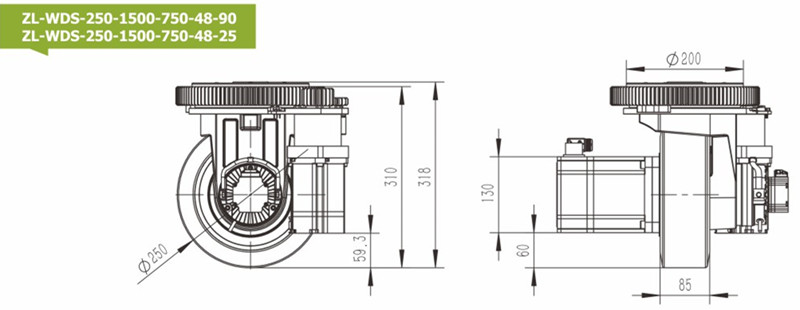
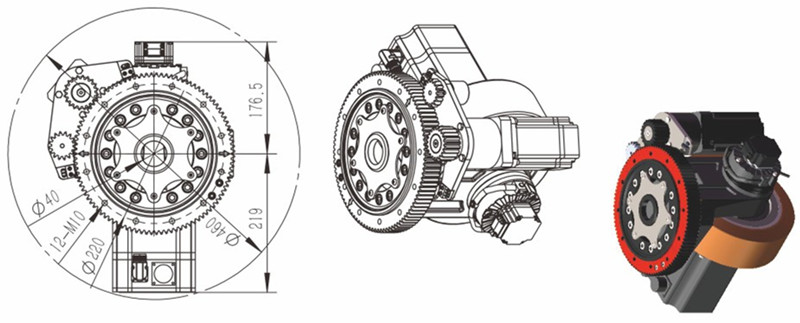
ZL-WDS-250-1500-750-48-90(25)
| Traction motor parameters | Motor Power | Motor Voltage | Motor speed | Motor current | Rated torque | IP Grade | Encoder | ||
| Type | DC | W | V | RPM | A | Nm | IP | Magnetic braiding | Resolution ratio |
| Servo Motor | 1500 | 48 | 3000 | 37.4 | 5 | 65 | Increment | 1024 | |
| Traction reducer parameters | Type | X | Planetary reducer | Steering motor parameters | Type | DC | Servo Motor | ||
| Reducer speed ratio | i | 25 | 85 | Motor Power | W | 750 | |||
| Reducer torque | Nm | 250 | 310 | Motor Voltage | V | 48 | |||
| Polyurethane Loaded | Kg | 2000 | Motor speed | RPM | 3000 | ||||
| Rubber Loaded | Kg | 1800 | Motor current | A | 19 | ||||
| Braking torque | Nm | 190 | 646 | Reducer speed ratio | i | 35+(100:20) | |||
| Actuators torque | Nm | 8 | 8 | Reducer torque | Nm | 105 | |||
| Actuators Voltage | V | DC24 | DC24 | IP Grade | IP | 65 | |||
| Maximum speed | M/min | 94.2 | 27.7 | Encoder | Magnetic braiding | Increment | |||
| Traction | N | 950 | 1700 | Resolution ratio | 1024 | ||||
| Traction weight | reference | 1425 | 2550 | Left and right limit | IO | Always on, always off | |||
| Max steering Angle | ± | 140° | |||||||
| Another | Reducer lubrication | lubricant | (-20°~200°) | ||||||
| Dead-weight | Kg | About30 | |||||||
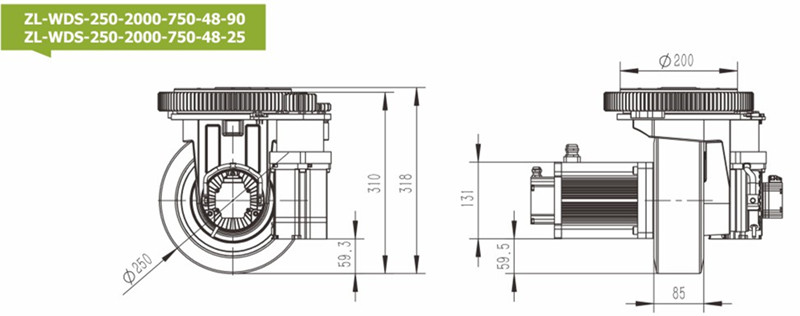
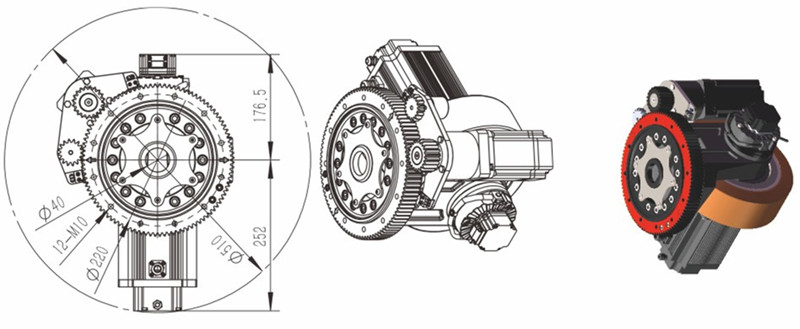
ZL-WDS-250-2000-750-48-90(25)
| Traction motor parameters | Motor Power | Motor Voltage | Motor speed | Motor current | Rated torque | IP Grade | Encoder | ||
| Type | DC | W | V | RPM | A | Nm | IP | Magnetic braiding | Resolution ratio |
| Servo Motor | 2000 | 48 | 3000 | 73.5 | 7.3 | 65 | Increment | 1024 | |
| Traction reducer parameters | Type | X | Planetary reducer | Steering motor parameters | Type | DC | Servo Motor | ||
| Reducer speed ratio | i | 25 | 85 | Motor Power | W | 750 | |||
| Reducer torque | Nm | 250 | 310 | Motor Voltage | V | 48 | |||
| Polyurethane Loaded | Kg | 2000 | Motor speed | RPM | 3000 | ||||
| Rubber Loaded | Kg | 1800 | Motor current | A | 19 | ||||
| Braking torque | Nm | 190 | 646 | Reducer speed ratio | i | 35+(100:20) | |||
| Actuators torque | Nm | 8 | 8 | Reducer torque | Nm | 105 | |||
| Actuators Voltage | V | DC24 | DC24 | IP Grade | IP | 65 | |||
| Maximum speed | M/min | 94.2 | 27.7 | Encoder | Magnetic braiding | Increment | |||
| Traction | N | 1387 | 2482 | Resolution ratio | 1024 | ||||
| Traction weight | reference | 2081 | 3723 | Left and right limit | IO | Always on, always off | |||
| Max steering Angle | ± | 140° | |||||||
| Another | Reducer lubrication | lubricant | (-20°~200°) | ||||||
| Dead-weight | Kg | About32 | |||||||
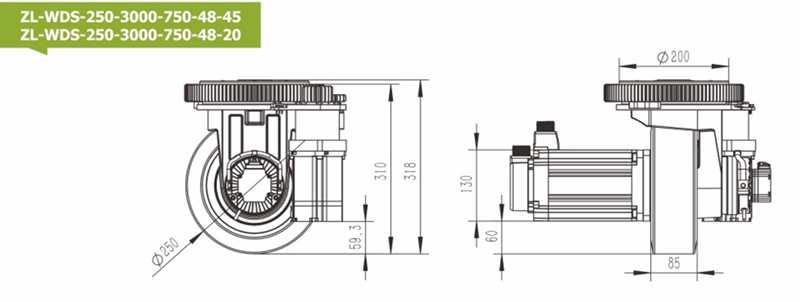
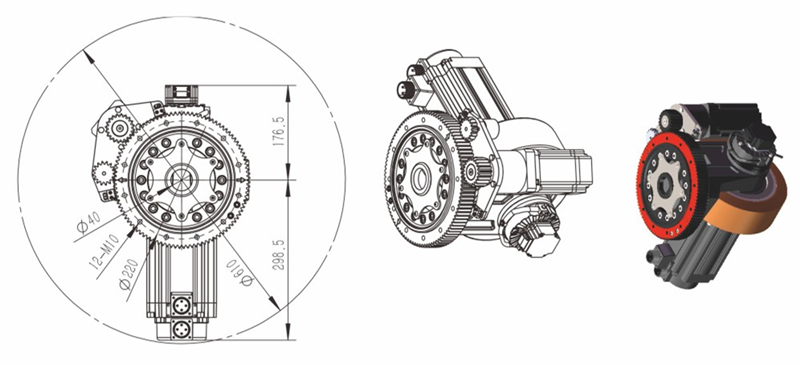
ZL-WDS-250-3000-750-48-90(25)
| Traction motor parameters | Motor Power | Motor Voltage | Motor speed | Motor current | Rated torque | IP Grade | Encoder | ||
| Type | DC | W | V | RPM | A | Nm | IP | Magnetic braiding | Resolution ratio |
| Servo Motor | 3000 | 48 | 1500 | 80 | 19.1 | 65 | Increment | 1024 | |
| Traction reducer parameters | Type | X | Planetary reducer | Steering motor parameters | Type | DC | Servo Motor | ||
| Reducer speed ratio | i | 25 | 56 | Motor Power | W | 750 | |||
| Reducer torque | Nm | 250 | 310 | Motor Voltage | V | 48 | |||
| Polyurethane Loaded | Kg | 2000 | Motor speed | RPM | 3000 | ||||
| Rubber Loaded | Kg | 1800 | Motor current | A | 19 | ||||
| Braking torque | Nm | 190 | 425.6 | Reducer speed ratio | i | 35+(100:20) | |||
| Actuators torque | Nm | 8 | 8 | Reducer torque | Nm | 105 | |||
| Actuators Voltage | V | DC24 | DC24 | IP Grade | IP | 65 | |||
| Maximum speed | M/min | 47.1 | 21 | Encoder | Magnetic braiding | Increment | |||
| Traction | N | 3056 | 4278.4 | Resolution ratio | 1024 | ||||
| Traction weight | reference | 4584 | 6417.6 | Left and right limit | IO | Always on, always off | |||
| Max steering Angle | ± | 140° | |||||||
| Another | Reducer lubrication | lubricant | (-20°~200°) | ||||||
| Dead-weight | Kg | About35 | |||||||