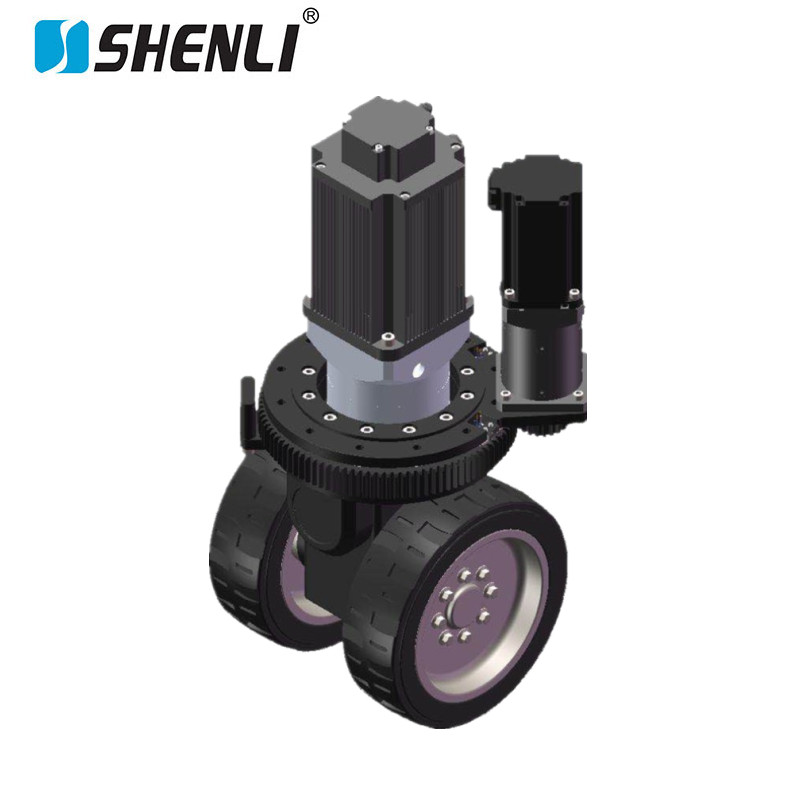
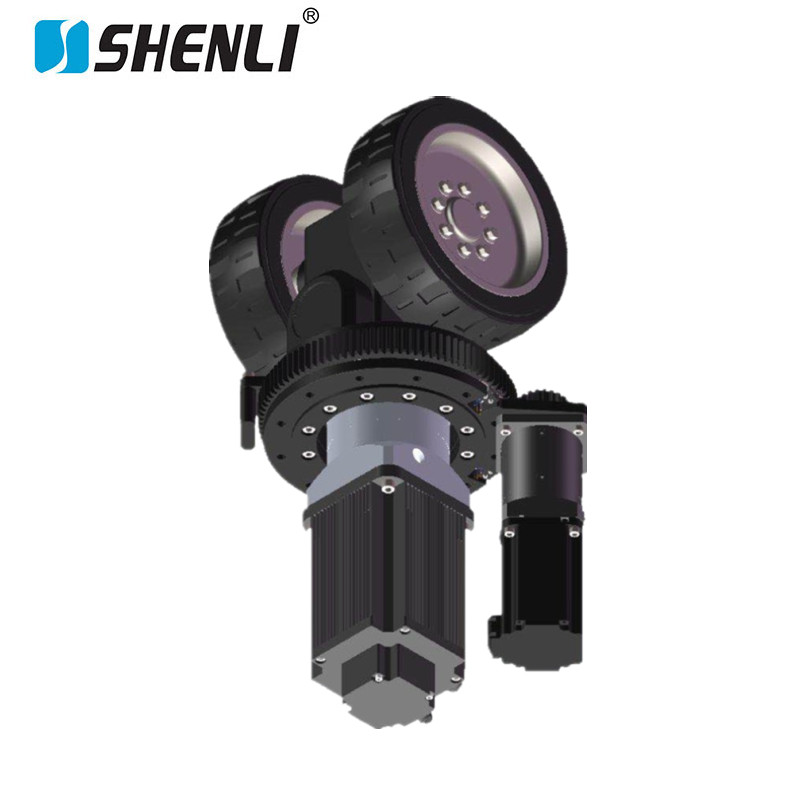
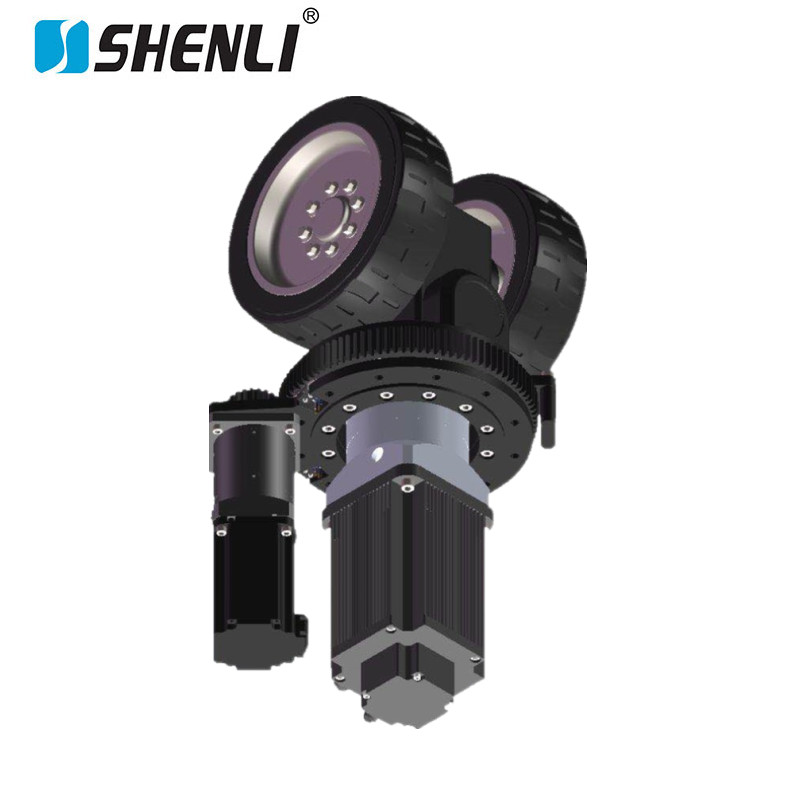
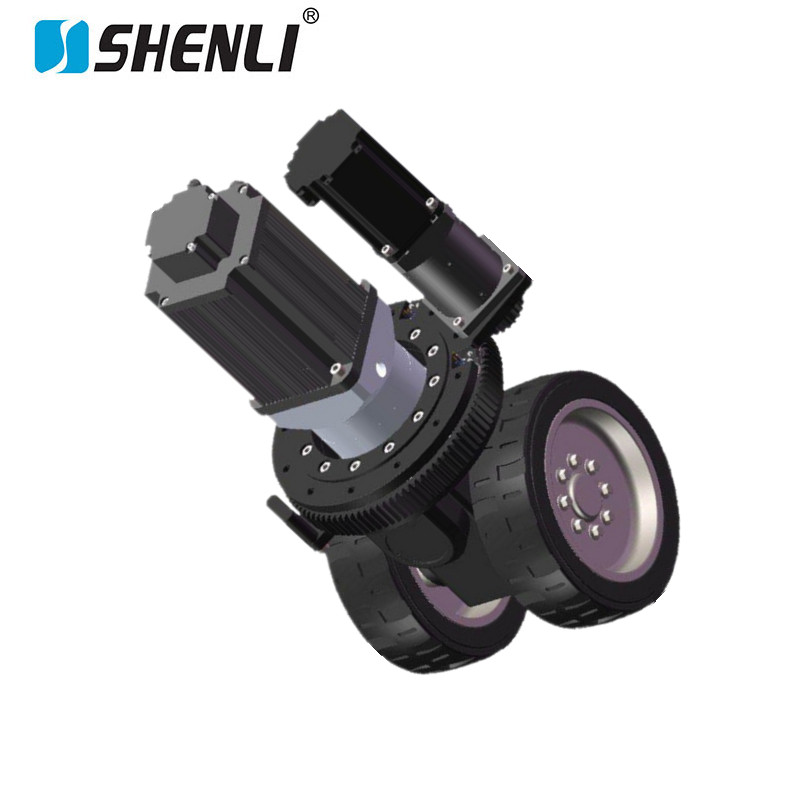


Description
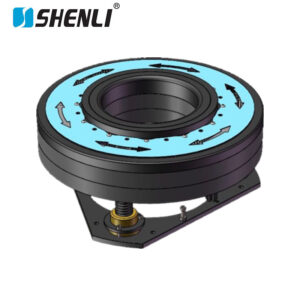
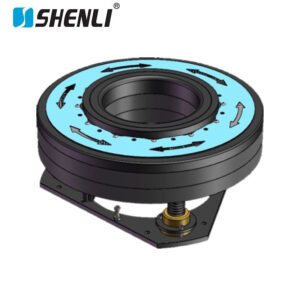
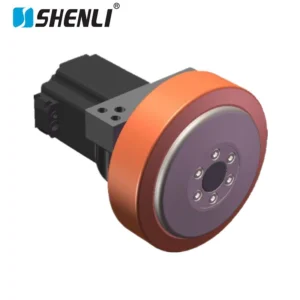
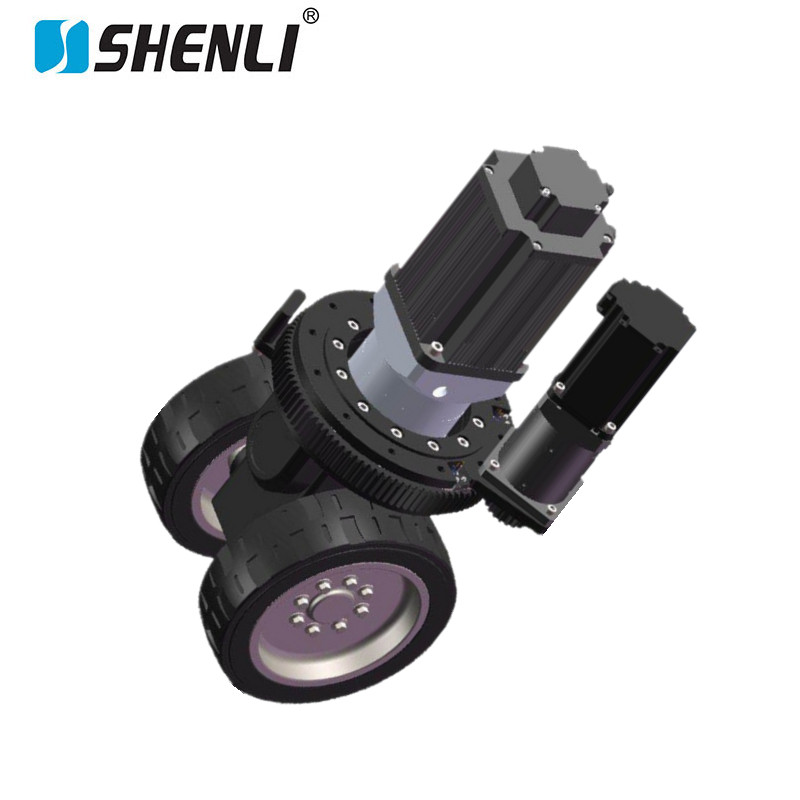
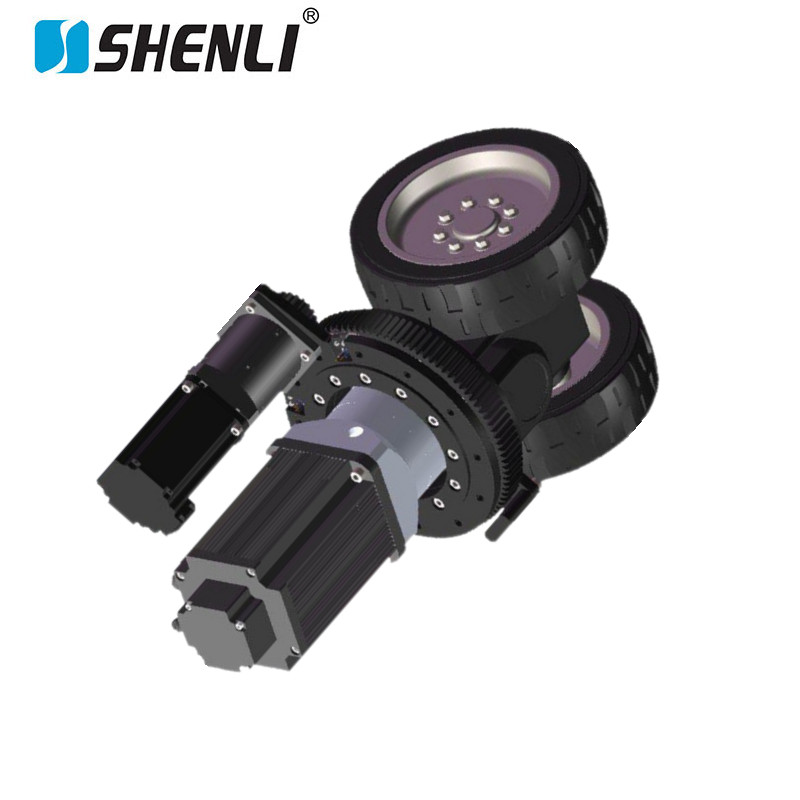
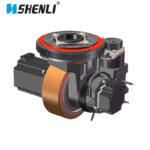
LDSS Vertical Steering Wheel – Complete Technical Specifications
1. Basic Information
- Product Model: LDSS Vertical Steering Wheel
- Product Type: Industrial Vertical Steering Wheel / Vertical Steering Module
- Applicable Equipment: AGV (Automated Guided Vehicle), RGV (Rail Guided Vehicle), industrial transport carts, automated production lines, logistics conveyor platforms
- Drive Mode: Compatible with drive motors or passive rolling systems
- Main Functions: Vertical steering, multidirectional movement, precise positioning
2. Mechanical Specifications
- Wheel Diameter: 50 mm – 300 mm (customizable)
- Wheel Width: 20 mm – 100 mm (depending on model)
- Wheel Material: High-strength alloy steel/nylon / PU polyurethane/rubber
- Hub Material: Aluminum alloy/steel/nylon
- Bearing Type: Deep groove ball bearing/needle roller bearing / high-speed ball bearing
- Rim Structure: Single groove / double groove / flanged rim
- Mounting Bore Diameter: 6 mm – 25 mm (customizable)
- Bearing Lubrication Method: Sealed lubrication/grease injection lubrication
3. Load & Motion Specifications
- Rated Load Capacity: 50 kg – 1000 kg (depending on wheel size and material)
- Maximum Load Capacity: Up to 2 times the rated load for short-term operation
- Maximum Rotational Speed: 2000 rpm
- Friction Coefficient: 0.02 – 0.05 (low-friction rolling performance)
- Rolling Resistance: ≤5 N (varies depending on wheel material)
- Repeat Positioning Accuracy: ±0.1 mm (when used with guide rails)
4. Environmental & Durability Specifications
- Operating Temperature Range: -20°C to +80°C
- Storage Temperature Range: -40°C to +100°C
- Humidity Resistance: 10% – 95% RH (non-condensing)
- Wear Resistance: ≥200,000 operating cycles (under test conditions)
- Corrosion Resistance: Optional galvanized or anti-rust surface treatment
- Vibration Resistance: Compliant with IEC60068-2-6 standard
- Noise Level: ≤55 dB (PU/nylon wheel versions)
5. Structural & Interface Specifications
- Flange Height: Customizable from 5 mm – 20 mm
- Hub Thickness: 10 mm – 50 mm
- Bearing Clearance: 0.01 – 0.03 mm
- Mounting Method: Bolt fixation/shaft insertion / embedded mounting
- Dust Protection: Optional rubber dust seal or metal cover
6. Special Features & Optional Configurations
- High-Temperature Wheel Materials: High-temperature nylon or steel wheel optional
- Electrostatic Protection: Optional anti-static coating
- Anti-Slip Surface: PU or rubber surface treatment available
- Custom Load Ratings: Custom-designed according to customer requirements
- Combined Wheel Assemblies: Compatible with sprocket wheels and gear wheels
- Color Identification: Red/black/blue options for easy identification
7. Typical Applications
- Vertical steering systems for AGV automated guided vehicles
- Vertical steering wheels for RGV rail guided vehicles
- Industrial transport carts and conveyor platforms
- Material handling systems for automated production lines
- Warehouse logistics transport equipment
- Vertical steering systems for robotic mobile platforms
- High-precision positioning tables and rotary platforms
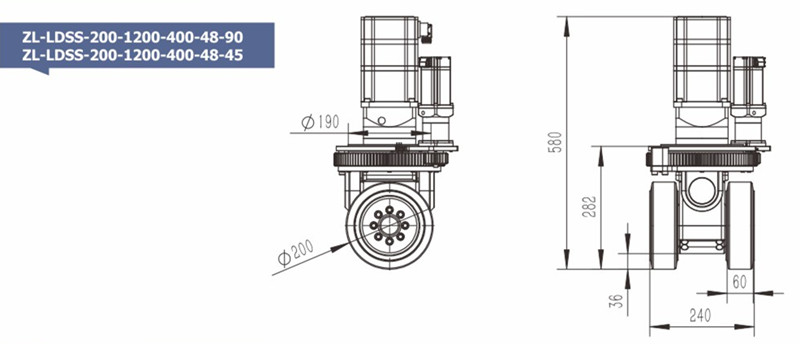
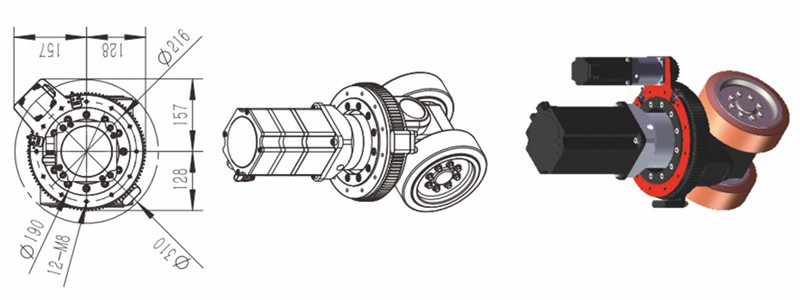
ZL-LDSS-200-1200-400-48-90(45)
| Traction motor parameters | Motor Power | Motor Voltage | Motor speed | Motor current | Rated torque | IP Grade | Encoder | ||
| Type | DC | W | V | RPM | A | Nm | IP | Magnetic braiding | Resolution ratio |
| Servo Motor | 1200 | 48 | 3000 | 31.6 | 3.8 | 65 | Increment | 1024 | |
| Traction reducer parameters | Type | X | Planetary reducer | Steering motor parameters | Type | DC | Servo Motor | ||
| Reducer speed ratio | i | 20 | 40 | Motor Power | W | 400 | |||
| Reducer torque | Nm | 350 | 400 | Motor Voltage | V | 48 | |||
| Polyurethane Loaded | Kg | 1500 | Motor speed | RPM | 3000 | ||||
| Rubber Loaded | Kg | 1380 | Motor current | A | 10.1 | ||||
| Braking torque | Nm | 57 | 114 | Reducer speed ratio | i | 35+(100:20) | |||
| Actuators torque | Nm | 3 | 3 | Reducer torque | Nm | 35 | |||
| Actuators Voltage | V | DC24 | DC24 | IP Grade | IP | 65 | |||
| Maximum speed | M/min | 94.2 | 47.1 | Encoder | Magnetic braiding | Increment | |||
| Traction | N | 722 | 1368 | Resolution ratio | 1024 | ||||
| Traction weight | reference | 1083 | 2052 | Left and right limit | IO | Always on, always off | |||
| Max steering Angle | ± | 140° | |||||||
| Another | Reducer lubrication | lubricant | (-20°~200°) | ||||||
| Dead-weight | Kg | About 33 | |||||||
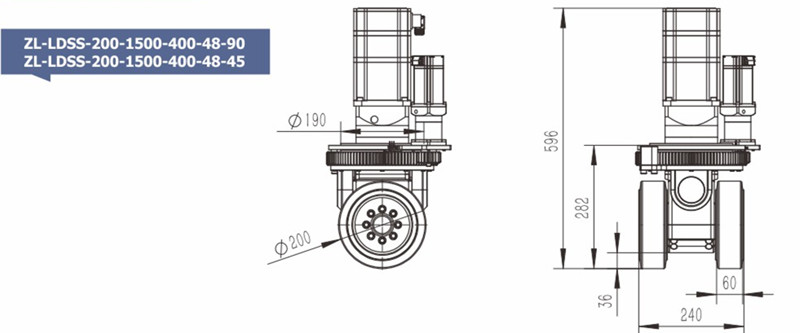
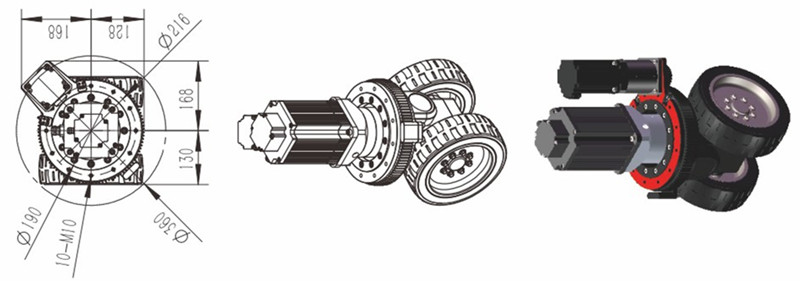
ZL-LDSS-200-1500-4000-48-90(45)
| Traction motor parameters | Motor Power | Motor Voltage | Motor speed | Motor current | Rated torque | IP Grade | Encoder | ||
| Type | DC | W | V | RPM | A | Nm | IP | Magnetic braiding | Resolution ratio |
| Servo Motor | 1500 | 48 | 3000 | 37.4 | 5 | 65 | Increment | 1024 | |
| Traction reducer parameters | Type | X | Planetary reducer | Steering motor parameters | Type | DC | Servo Motor | ||
| Reducer speed ratio | i | 20 | 40 | Motor Power | W | 400 | |||
| Reducer torque | Nm | 350 | 400 | Motor Voltage | V | 48 | |||
| Polyurethane Loaded | Kg | 1500 | Motor speed | RPM | 3000 | ||||
| Rubber Loaded | Kg | 1380 | Motor current | A | 10.1 | ||||
| Braking torque | Nm | 57 | 114 | Reducer speed ratio | i | 35+(100:20) | |||
| Actuators torque | Nm | 3 | 3 | Reducer torque | Nm | 35 | |||
| Actuators Voltage | V | DC24 | DC24 | IP Grade | IP | 65 | |||
| Maximum speed | M/min | 94.2 | 47.1 | Encoder | Magnetic braiding | Increment | |||
| Traction | N | 950 | 1800 | Resolution ratio | 1024 | ||||
| Traction weight | reference | 1425 | 2700 | Left and right limit | IO | Always on, always off | |||
| Max steering Angle | ± | 140° | |||||||
| Another | Reducer lubrication | lubricant | (-20°~200°) | ||||||
| Dead-weight | Kg | About 33 | |||||||
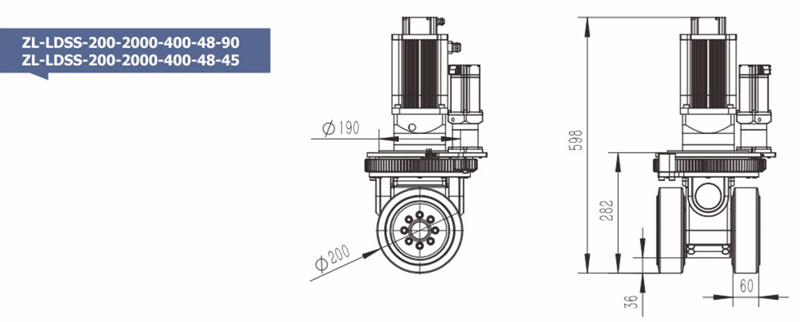
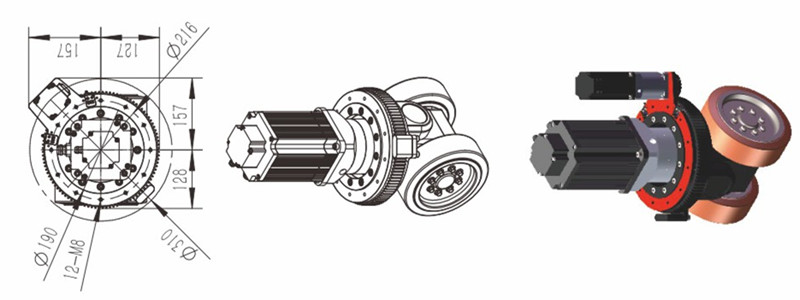
ZL-LDSS-200-2000-400-48-90(45)
| Traction motor parameters | Motor Power | Motor Voltage | Motor speed | Motor current | Rated torque | IP Grade | Encoder | ||
| Type | DC | W | V | RPM | A | Nm | IP | Magnetic braiding | Resolution ratio |
| Servo Motor | 2000 | 48 | 3000 | 67 | 7.3 | 65 | Increment | 1024 | |
| Traction reducer parameters | Type | X | Planetary reducer | Steering motor parameters | Type | DC | Servo Motor | ||
| Reducer speed ratio | i | 20 | 40 | Motor Power | W | 400 | |||
| Reducer torque | Nm | 350 | 400 | Motor Voltage | V | 48 | |||
| Polyurethane Loaded | Kg | 1500 | Motor speed | RPM | 3000 | ||||
| Rubber Loaded | Kg | 1380 | Motor current | A | 10.1 | ||||
| Braking torque | Nm | 57 | 114 | Reducer speed ratio | i | 35+(100:20) | |||
| Actuators torque | Nm | 3 | 3 | Reducer torque | Nm | 35 | |||
| Actuators Voltage | V | DC24 | DC24 | IP Grade | IP | 65 | |||
| Maximum speed | M/min | 94.2 | 47.1 | Encoder | Magnetic braiding | Increment | |||
| Traction | N | 1387 | 2628 | Resolution ratio | 1024 | ||||
| Traction weight | reference | 2081 | 3942 | Left and right limit | IO | Always on, always off | |||
| Max steering Angle | ± | 140° | |||||||
| Another | Reducer lubrication | lubricant | (-20°~200°) | ||||||
| Dead-weight | Kg | About 35 | |||||||
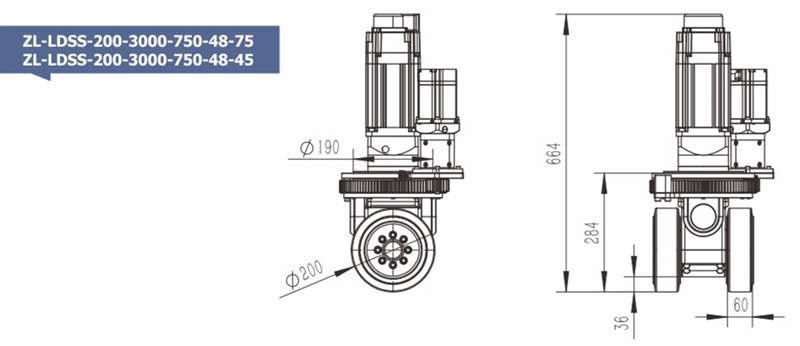
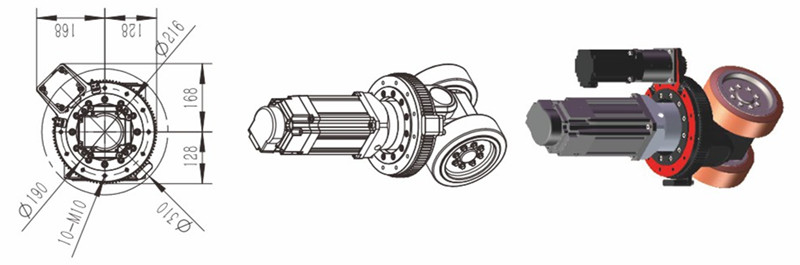
ZL-LDSS-200-3000-750-48-75(45)
| Traction motor parameters | Motor Power | Motor Voltage | Motor speed | Motor current | Rated torque | IP Grade | Encoder | ||
| Type | DC | W | V | RPM | A | Nm | IP | Magnetic braiding | Resolution ratio |
| Servo Motor | 3000 | 48 | 1500 | 80 | 19.1 | 65 | Increment | 1024 | |
| Traction reducer parameters | Type | X | Planetary reducer | Steering motor parameters | Type | DC | Servo Motor | ||
| Reducer speed ratio | i | 12 | 20 | Motor Power | W | 750 | |||
| Reducer torque | Nm | 350 | 400 | Motor Voltage | V | 48 | |||
| Polyurethane Loaded | Kg | 1500 | Motor speed | RPM | 3000 | ||||
| Rubber Loaded | Kg | 1380 | Motor current | A | 19 | ||||
| Braking torque | Nm | 34.2 | 57 | Reducer speed ratio | i | 35+(100:20) | |||
| Actuators torque | Nm | 3 | 3 | Reducer torque | Nm | 105 | |||
| Actuators Voltage | V | DC24 | DC24 | IP Grade | IP | 65 | |||
| Maximum speed | M/min | 78.5 | 47.1 | Encoder | Magnetic braiding | Increment | |||
| Traction | N | 2177 | 3438 | Resolution ratio | 1024 | ||||
| Traction weight | reference | 3266 | 5157 | Left and right limit | IO | Always on, always off | |||
| Max steering Angle | ± | 140° | |||||||
| Another | Reducer lubrication | lubricant | (-20°~200°) | ||||||
| Dead-weight | Kg | About 36 | |||||||
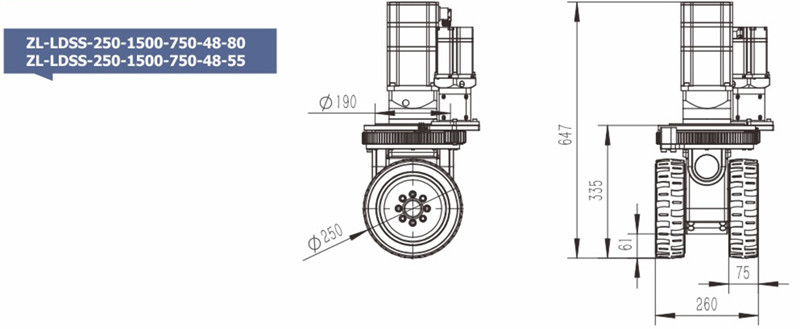
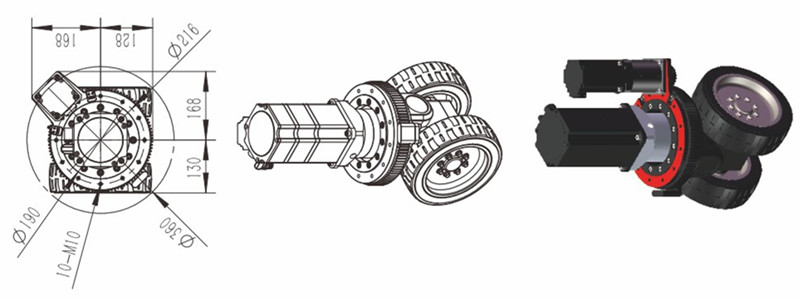
ZL-LDSS-250-1500-750-48-80(55)
| Traction motor parameters | Motor Power | Motor Voltage | Motor speed | Motor current | Rated torque | IP Grade | Encoder | ||
| Type | DC | W | V | RPM | A | Nm | IP | Magnetic braiding | Resolution ratio |
| Servo Motor | 1500 | 48 | 3000 | 37.4 | 5 | 65 | Increment | 1024 | |
| Traction reducer parameters | Type | X | Planetary reducer | Steering motor parameters | Type | DC | Servo Motor | ||
| Reducer speed ratio | i | 28 | 40 | Motor Power | W | 750 | |||
| Reducer torque | Nm | 350 | 400 | Motor Voltage | V | 48 | |||
| Polyurethane Loaded | Kg | 2000 | Motor speed | RPM | 3000 | ||||
| Rubber Loaded | Kg | 1800 | Motor current | A | 19 | ||||
| Braking torque | Nm | 79.8 | 114 | Reducer speed ratio | i | 35+(100:20) | |||
| Actuators torque | Nm | 3 | 3 | Reducer torque | Nm | 105 | |||
| Actuators Voltage | V | DC24 | DC24 | IP Grade | IP | 65 | |||
| Maximum speed | M/min | 84.1 | 58.9 | Encoder | Magnetic braiding | Increment | |||
| Traction | N | 1064 | 1440 | Resolution ratio | 1024 | ||||
| Traction weight | reference | 1596 | 2160 | Left and right limit | IO | Always on, always off | |||
| Max steering Angle | ± | 140° | |||||||
| Another | Reducer lubrication | lubricant | (-20°~200°) | ||||||
| Dead-weight | Kg | About 42 | |||||||
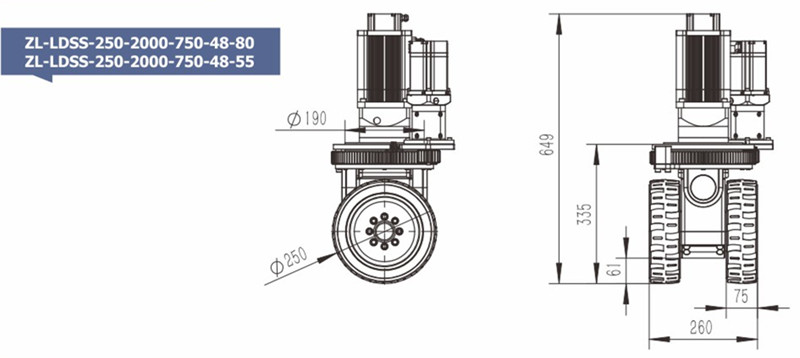
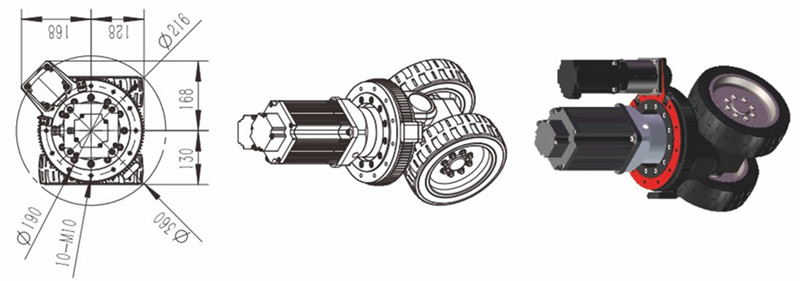
ZL-LDSS-250-2000-750-48-80(56)
| Traction motor parameters | Motor Power | Motor Voltage | Motor speed | Motor current | Rated torque | IP Grade | Encoder | ||
| Type | DC | W | V | RPM | A | Nm | IP | Magnetic braiding | Resolution ratio |
| Servo Motor | 2300 | 48 | 3000 | 67 | 7.3 | 65 | Increment | 1024 | |
| Traction reducer parameters | Type | X | Planetary reducer | Steering motor parameters | Type | DC | Servo Motor | ||
| Reducer speed ratio | i | 28 | 40 | Motor Power | W | 750 | |||
| Reducer torque | Nm | 350 | 400 | Motor Voltage | V | 48 | |||
| Polyurethane Loaded | Kg | 2000 | Motor speed | RPM | 3000 | ||||
| Rubber Loaded | Kg | 1800 | Motor current | A | 19 | ||||
| Braking torque | Nm | 79.8 | 114 | Reducer speed ratio | i | 35+(100:20) | |||
| Actuators torque | Nm | 3 | 3 | Reducer torque | Nm | 105 | |||
| Actuators Voltage | V | DC24 | DC24 | IP Grade | IP | 65 | |||
| Maximum speed | M/min | 84.1 | 58.9 | Encoder | Magnetic braiding | Increment | |||
| Traction | N | 1553 | 2102.4 | Resolution ratio | 1024 | ||||
| Traction weight | reference | 2330 | 3153.6 | Left and right limit | IO | Always on, always off | |||
| Max steering Angle | ± | 140° | |||||||
| Another | Reducer lubrication | lubricant | (-20°~200°) | ||||||
| Dead-weight | Kg | About 43 | |||||||
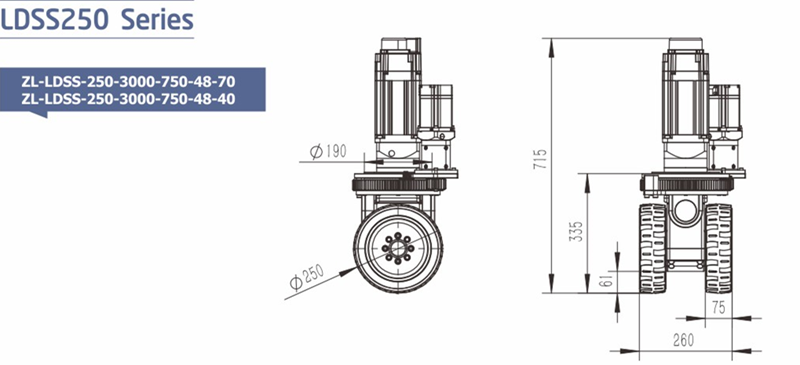
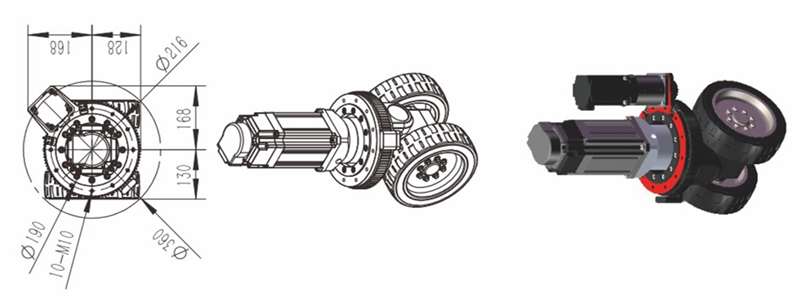
ZL-LDSS-250-3000-750-48-70(40)
| Traction motor parameters | Motor Power | Motor Voltage | Motor speed | Motor current | Rated torque | IP Grade | Encoder | ||
| Type | DC | W | V | RPM | A | Nm | IP | Magnetic braiding | Resolution ratio |
| Servo Motor | 3000 | 48 | 1500 | 80 | 19.1 | 65 | Increment | 1024 | |
| Traction reducer parameters | Type | X | Planetary reducer | Steering motor parameters | Type | DC | Servo Motor | ||
| Reducer speed ratio | i | 16 | 28 | Motor Power | W | 750 | |||
| Reducer torque | Nm | 350 | 450 | Motor Voltage | V | 48 | |||
| Polyurethane Loaded | Kg | 2000 | Motor speed | RPM | 3000 | ||||
| Rubber Loaded | Kg | 1800 | Motor current | A | 19 | ||||
| Braking torque | Nm | 60.8 | 106.4 | Reducer speed ratio | i | 35+(100:20) | |||
| Actuators torque | Nm | 4 | 4 | Reducer torque | Nm | 105 | |||
| Actuators Voltage | V | DC24 | DC24 | IP Grade | IP | 65 | |||
| Maximum speed | M/min | 73.6 | 42.1 | Encoder | Magnetic braiding | Increment | |||
| Traction | N | 2323 | 3422.72 | Resolution ratio | 1024 | ||||
| Traction weight | reference | 3484 | 5134.08 | Left and right limit | IO | Always on, always off | |||
| Max steering Angle | ± | 140° | |||||||
| Another | Reducer lubrication | lubricant | (-20°~200°) | ||||||
| Dead-weight | Kg | About 45 | |||||||