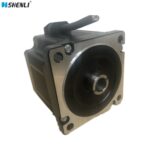

Description
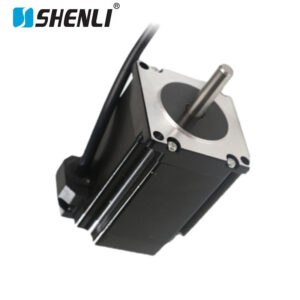
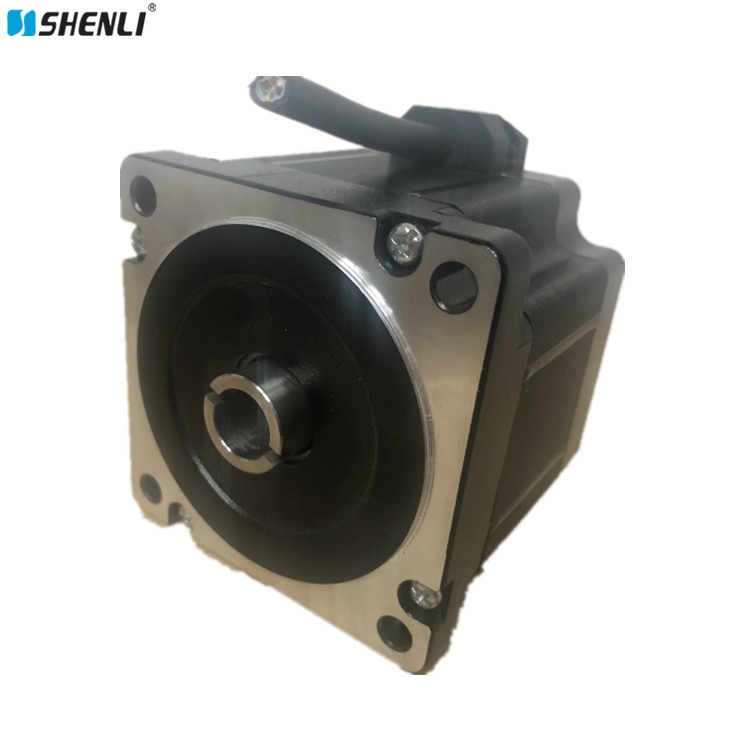
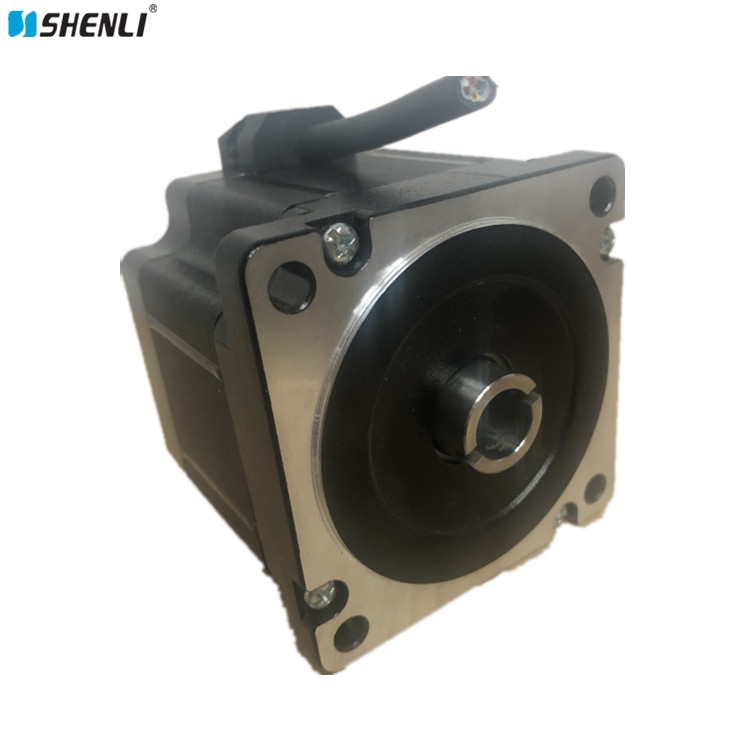
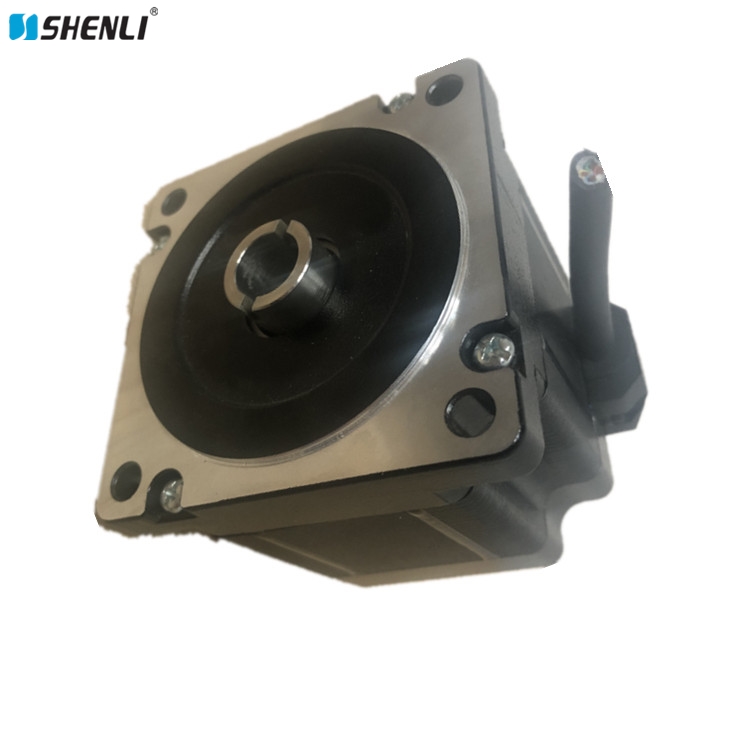
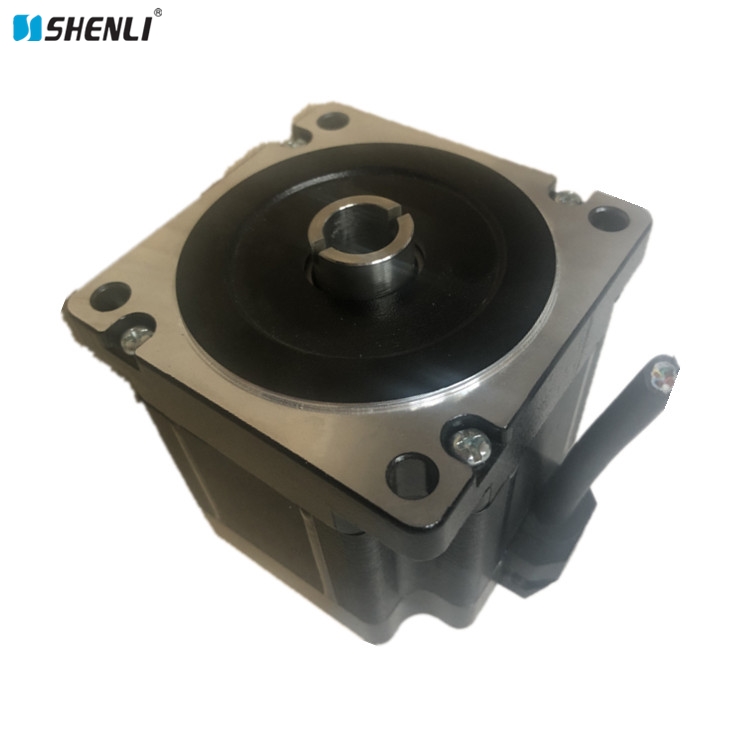
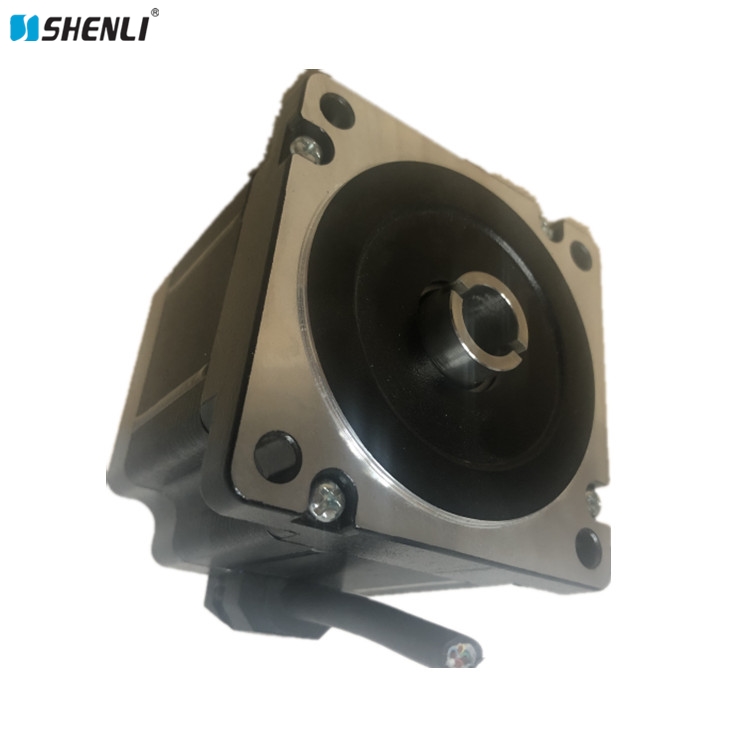
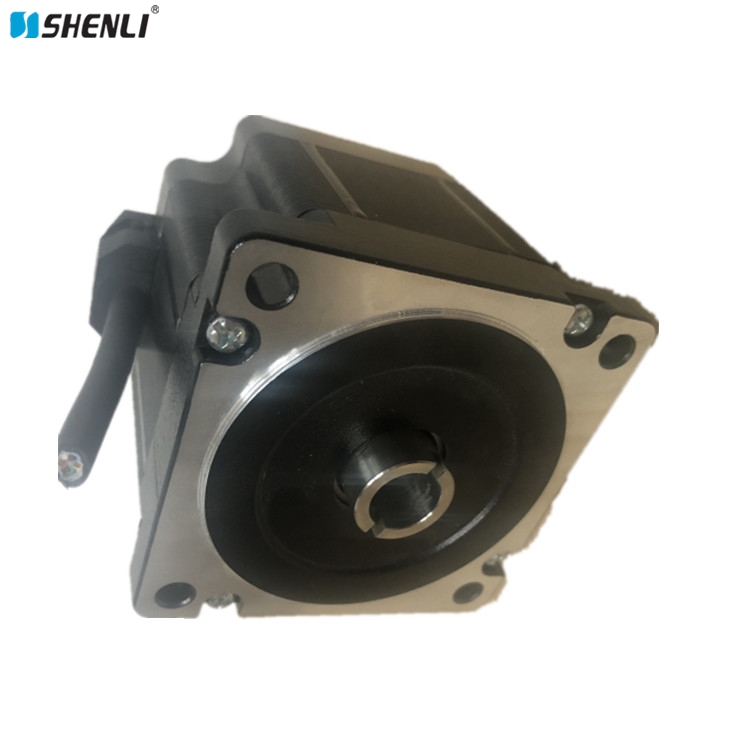
NEMA34 Hollow Shaft Stepper Motor for Industrial Automation
The NEMA34 hollow shaft stepper motor is designed for industrial automation systems that require precise motion control, high torque capability, and flexible mechanical integration. Its central bore allows cables, air tubes, and optical fibers to pass through the motor, helping simplify equipment layouts and reduce external routing requirements.
Built around hybrid stepper motor technology, this motor supports demanding motion applications, including industrial robotics, rotary indexing systems, semiconductor equipment, and automated production lines.
Key Features and Benefits
- Hollow Shaft Design: Provides a central passage for cables, pneumatic tubing, and optical fibers to support compact machine integration.
- High-Torque Motion Control: Designed for applications involving demanding loads and high-inertia motion systems.
- Precise Positioning: Supports controlled positioning and microstepping when paired with a compatible drive and control system.
- Industrial Construction: Precision-manufactured components support consistent operation in demanding equipment environments.
- Flexible System Integration: The hollow shaft can simplify the integration of compatible rotary unions and other mechanical components.
- OEM and ODM Customization: Custom motor configurations can be evaluated according to equipment requirements and integration constraints.
Hollow Shaft Design for Compact Machine Integration
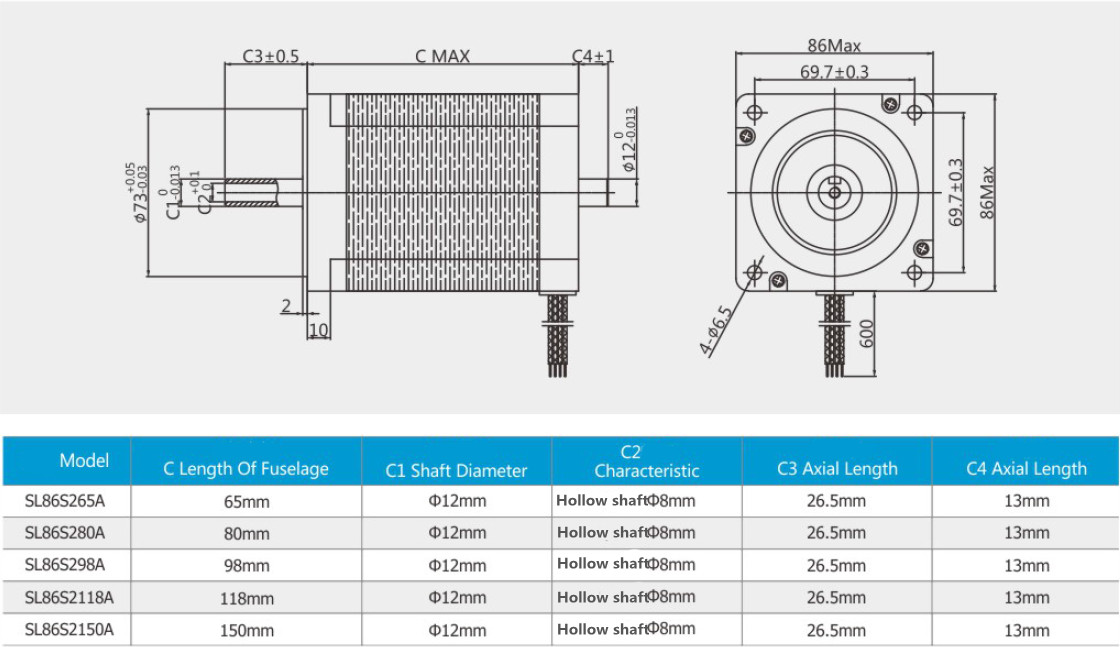
Unlike a conventional solid-shaft configuration, a hollow shaft stepper motor provides a passage through its center. This structure can accommodate selected cables, air tubes, and optical fibers, helping equipment designers optimize internal routing.
The design is particularly useful in machinery where space is limited or where wiring and tubing must pass through a rotating assembly. It can also improve access to selected components during installation and maintenance, depending on the overall mechanical layout.
For equipment manufacturers, the hollow shaft structure offers greater flexibility when designing compact motion platforms, rotary mechanisms, and automated production systems.
High Torque and Precise Motion Control
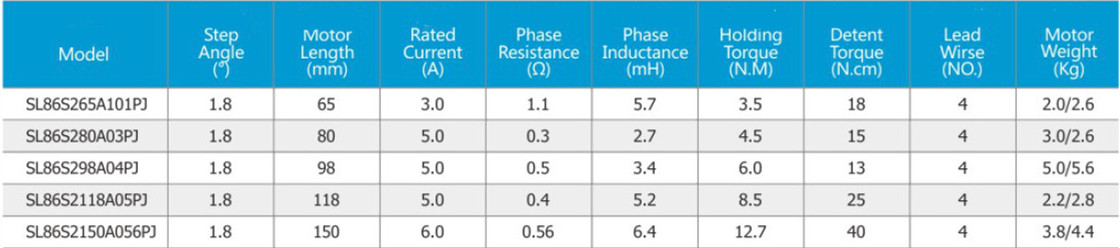
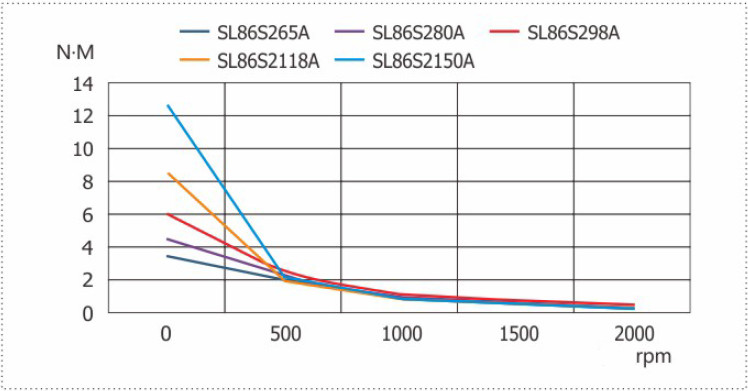
The NEMA34 frame size is commonly considered for motion systems that require a larger motor mounting envelope and substantial torque capability. Actual output torque and positioning performance depend on the motor model, operating speed, drive current, supply voltage, and mechanical load.
Hybrid stepper technology enables controlled incremental motion. When used with a compatible stepper drive, the motor can support microstepping for smoother motion and finer command resolution.
Key design considerations include:
- Load requirements: Evaluate load inertia, acceleration, deceleration, and required holding torque.
- Operating speed: Confirm the available torque across the intended speed range.
- Positioning needs: Match the motor and drive to the application’s resolution and motion profile.
- Thermal performance: Check temperature rise under the expected duty cycle and installation conditions.
- Feedback requirements: Consider encoder integration when the control system requires position feedback or additional monitoring.
These factors help determine whether a specific hollow shaft stepper motor is suitable for the intended automation system.
Industrial Manufacturing and Reliability
Motor performance depends on the quality of its magnetic circuit, stator construction, bearings, assembly, and inspection procedures. The described motor design uses high-performance rare-earth magnetic materials and precision-laminated stator construction to support electromagnetic performance and motion stability.
Manufacturing quality checks may include dimensional inspection, operational testing, and load verification. Aging tests can also be used as part of a manufacturer’s quality assurance process, depending on the product specification.
For applications involving continuous operation, buyers should confirm the motor’s rated operating conditions, thermal limits, bearing specifications, expected service life, and available test documentation before selection.
Typical Applications
The NEMA34 hollow shaft stepper motor can be evaluated for a range of industrial motion applications where a central passage and controlled positioning are beneficial.
| Application | Potential Benefit of Hollow Shaft Design |
|---|---|
| Industrial robot joints | Provides routing options for selected cables and signal lines |
| Rotary indexing tables | Supports compact integration around rotating assemblies |
| Semiconductor manufacturing equipment | Helps organize wiring in space-constrained machinery |
| Automated assembly lines | Supports repeatable positioning in configured motion systems |
| Laser processing machines | Provides a routing option for compatible optical fibers and cables |
| Smart warehousing systems | Supports motion control in automated handling equipment |
| New energy production equipment | Can be integrated into selected automated manufacturing processes |
| Packaging machinery | Helps accommodate wiring or tubing in suitable rotary mechanisms |
Final suitability depends on the required torque, speed, mechanical interface, duty cycle, and environmental conditions.